Guide driving route planners multiple optimize smart navigation

Table of Contents
- Core Features of Route Planners for Guided Driving
- Key Functionalities Differentiating Advanced Route Planners
- Comparison: Traditional GPS vs. Modern Guided Driving Route Planners
- Adaptation to Dynamic Conditions: Mechanisms and User Actions
- User-Centric Design for Guided Driving Routes
- Designing an Accessible Interface for Elderly Drivers
- Implementing a Low-Stress Route Mode
- Interactive Elements to Enhance Trust and Reduce Anxiety
- Comparison of Route Planner Designs: Urban Commuters vs. Long-Distance Travelers
- Technical Integration for Multi-Stop Route Optimization
- Application of Optimization Algorithms in Multi-Stop Routes
- API Integration for Real-Time Data Fetching
- Balancing Optimization Factors via Weighted Scoring
- Structuring JSON Payloads for Route Planner Backends
- Accessibility and Inclusivity in Route Planning
- Underrepresented User Groups and Customizable Route Planner Features
- Accessibility Standards Checklist for Route Planners
- Assistive Technologies and Implementation Challenges
- Case Studies of Inclusive Route Planner Implementations
- Advanced Visualization Techniques for Route Guidance
- Augmented Reality Overlays for In-Car Navigation
- Generating 3D Terrain Models for Off-Road and Rural Routes
- Designing Animated Progress Maps for Real-Time Vehicle Movement
- Heatmaps for Traffic Congestion and Route Popularity Visualization
Modern route planning has evolved far beyond basic turn-by-turn directions, integrating advanced algorithms and user-centric design to enhance guided driving experiences. From real-time traffic adaptation to accessibility features for diverse user groups, today’s multi-stop route planners combine technical precision with intuitive interfaces. This guide explores how cutting-edge functionalities—such as dynamic optimization, API-driven data integration, and augmented reality visualization—reshape navigation efficiency while addressing critical challenges in usability and inclusivity.
The intersection of technology and human-centered design creates opportunities for smarter, safer, and more adaptable driving solutions. Whether optimizing routes for urban commuters or long-distance travelers, or ensuring compliance with accessibility standards, the evolution of route planners reflects a shift toward personalized and resilient navigation systems. By examining core features, technical implementations, and visualization techniques, this discussion provides actionable insights for developers, designers, and end-users alike.
Core Features of Route Planners for Guided Driving
Advanced route planners for guided driving represent a paradigm shift from traditional GPS navigation by integrating real-time data, adaptive algorithms, and user-centric functionalities. Unlike basic navigation tools, which primarily rely on static maps and turn-by-turn directions, modern route planners incorporate dynamic adjustments, voice-guided assistance, and multi-stop optimization to enhance efficiency, safety, and accessibility. These systems are particularly valuable in logistics, tourism, and autonomous vehicle applications, where precision and adaptability are critical.The differentiation between advanced route planners and conventional GPS systems stems from their ability to process live inputs, predict disruptions, and optimize paths based on contextual factors such as traffic congestion, weather conditions, or user preferences. Below, the essential functionalities are categorized to highlight their technological underpinnings and practical applications.
Key Functionalities Differentiating Advanced Route Planners
Advanced route planners leverage a combination of AI, IoT, and cloud-based analytics to deliver superior performance. The following table outlines core features, their primary use cases, technological requirements, and real-world examples.| Feature Name | Primary Use Case | Technological Requirement | Example Application |
|---|---|---|---|
| Real-Time Traffic Integration | Dynamic rerouting to avoid congestion, accidents, or roadworks. | APIs for traffic data (e.g., Google Maps Traffic, HERE, TomTom), edge computing for low-latency processing. | Logistics fleets rerouting during peak hours; ride-sharing apps adjusting pickup/drop-off times. |
| Voice-Guided Instructions with Contextual Awareness | Hands-free navigation with adaptive voice prompts (e.g., lane changes, speed limits, points of interest). | Natural Language Processing (NLP), speech recognition (e.g., Google Assistant, Amazon Alexa), and gesture control APIs. | Autonomous shuttle services in airports; guided driving for visually impaired users. |
| Multi-Stop Optimization (Vehicle Routing Problem - VRP) | Efficient sequencing of stops to minimize distance/time while considering constraints (e.g., delivery windows, fuel stops). | Heuristic algorithms (e.g., Clarke-Wright Savings), machine learning for predictive modeling, and cloud-based optimization engines. | Amazon’s last-mile delivery routes; municipal waste collection scheduling. |
| Adaptive Speed and Route Adjustments | Automated speed limit compliance, hazard avoidance, and route recalculations based on sensor data. | LiDAR, radar, and camera inputs (for autonomous systems), or smartphone-based speed cameras (for guided driving). | Tesla’s Autopilot adaptive cruise control; guided driving for emergency response vehicles. |
| Integration with IoT and Telematics | Monitoring vehicle health, driver behavior, and external conditions (e.g., tire pressure, weather alerts). | IoT sensors (e.g., OBD-II ports), 5G connectivity, and predictive maintenance APIs. | Fleet management systems for rental cars; connected car ecosystems (e.g., BMW ConnectedDrive). |
| Offline and Low-Connectivity Mode | Navigation in remote areas or during network outages using pre-downloaded maps and cached data. | Local map databases (e.g., OSM, HERE Offline), compression algorithms for large datasets. | Military or disaster relief operations; guided driving in rural regions. |
| Personalized Route Customization | Tailoring routes based on user preferences (e.g., scenic paths, toll avoidance, electric vehicle charging stops). | User profiling via machine learning, preference APIs (e.g., Waze’s community-driven updates). | Tourism apps like Roadtrippers; EV-specific planners like PlugShare. |
Comparison: Traditional GPS vs. Modern Guided Driving Route Planners
Traditional GPS systems rely on static map data and basic turn-by-turn directions, lacking the adaptive capabilities required for dynamic environments. Modern route planners introduce three transformative advancements:1. Predictive and Adaptive Routing
Traditional GPS recalculates routes only after reaching a dead end or encountering a closed road, often leading to inefficiencies. Modern systems use predictive analytics to anticipate disruptions (e.g., accidents, construction) by integrating real-time feeds from traffic cameras, social media, and government databases. For example, Waze employs crowd-sourced data to predict congestion 15–30 minutes in advance, allowing proactive rerouting.
2. Context-Aware Voice and Multimodal Guidance
Basic GPS provides text or audio cues without adapting to the driver’s context. Advanced systems incorporate contextual voice prompts that adjust based on:
3. Autonomous Optimization of Multi-Objective Constraints
Traditional GPS treats each destination as an isolated point, while modern planners solve multi-objective optimization problems using:
Adaptation to Dynamic Conditions: Mechanisms and User Actions
Route planners mitigate disruptions through a combination of automated adjustments and user-triggered interventions. Below are the primary mechanisms and corresponding steps users can take to maximize effectiveness.Core Principle: Dynamic adaptation relies on a feedback loop between real-time data ingestion, algorithmic recalculation, and user confirmation.Automated Adjustments:
- Weather-Based Routing: Integration with NOAA, Met Office, or commercial weather APIs adjusts:
- Road Closure and Event Data: Crowdsourced or official sources (e.g., Google’s "Live Traffic" layer) flag:
User-Initiated Interventions:
Users can override or refine automated suggestions via:
1. Manual Overrides:
2. Real-Time Alerts Customization:
3. Collaborative Updates:
User-Centric Design for Guided Driving Routes
The design of a guided driving route planner must balance functionality with accessibility to accommodate diverse user needs, from urban commuters to elderly drivers. Key considerations include visual hierarchy, tactile feedback, and adaptive routing to avoid high-stress environments. Below, the focus shifts to wireframing an elderly-friendly interface, optimizing route complexity, and incorporating trust-building interactive features.
Designing an Accessible Interface for Elderly Drivers
An elderly-friendly route planner interface prioritizes legibility, simplicity, and error tolerance while adhering to WCAG 2.1 AA guidelines. The wireframe should feature:Visual Hierarchy Example:
A primary navigation bar at the top includes:
1. Route Overview (current location, destination, and simplified progress bar).
2. Action Buttons (e.g., "Recalculate Route," "Pause Navigation," "Call Emergency").
3. Status Indicators (e.g., "Low Stress Route Active," "Traffic Alert: Minor Delay").
Interactive Elements:
Implementing a Low-Stress Route Mode
Low-stress routing minimizes exposure to complex intersections, highways, and high-traffic areas by leveraging geospatial data and behavioral algorithms. The implementation involves:Step-by-Step Algorithm Design:
1. Data Layer:
2. Routing Logic:
3. User Preferences:
Example Workflow:
Interactive Elements to Enhance Trust and Reduce Anxiety
Interactive features serve as predictive cues and real-time reassurance, critical for users with limited spatial awareness or confidence in navigation systems. Key implementations include:Progress Visualization:
Predictive and Confirmatory Feedback:
Safety Net Features:
Comparison of Route Planner Designs: Urban Commuters vs. Long-Distance Travelers
Design priorities diverge based on user context, with urban commuters requiring speed and adaptability, while long-distance travelers prioritize predictability and comfort. Below is a functional and visual comparison of optimized designs for each group.
| Feature | Urban Commuter Design | Long-Distance Traveler Design |
|---|---|---|
| Primary Goal | Minimize travel time with real-time adjustments. | Maximize comfort with pre-planned stress avoidance. |
| Route Complexity | Dynamic rerouting via highways/major roads. | Static routes with manual overrides for detours. |
| Visual Style | Dark theme with neon highlights for urgency. | Light theme with muted colors for calmness. |
| Interactive Elements | Real-time traffic heatmaps and lane guidance. | Step-by-step turn-by-turn with audio cues. |
| Stress Mitigation | Alerts for sudden stops (e.g., "Brake for pedestrian"). | Avoids highways entirely; prefers toll roads for predictability. |
| Progress Tracking | ETA updates every 2 minutes. | Milestone-based (e.g., "Next: Rest stop in 45 miles"). |
| Emergency Features | Directs to nearest hospital or police station. | Includes breakdown assistance and fuel station alerts. |
| Data Integration | Public transit options and ride-sharing. | Weather forecasts and road condition updates. |
Example Use Case:
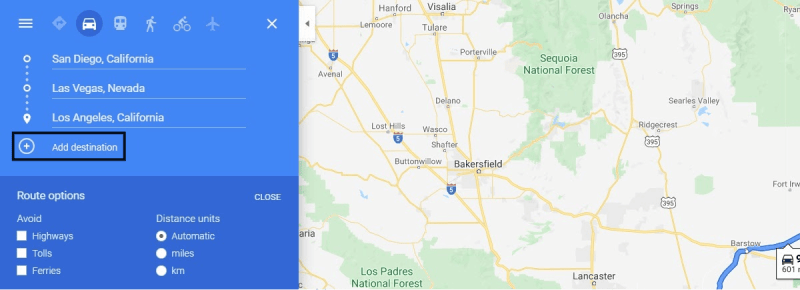
Technical Integration for Multi-Stop Route Optimization
Multi-stop route optimization in guided driving systems relies on advanced computational algorithms and real-time data integration to generate efficient, adaptive paths. These systems must balance conflicting priorities—such as minimizing travel time, reducing fuel consumption, and accommodating traffic conditions—while dynamically adjusting to user preferences and external variables. The foundation of this process involves leveraging mathematical optimization models like the Traveling Salesman Problem (TSP) and Vehicle Routing Problem (VRP), complemented by API-driven data feeds to ensure routes remain viable in real-world conditions.The interplay between algorithmic precision and real-time adaptability defines the robustness of route planners. For instance, a guided driving system for logistics may prioritize fuel efficiency over speed, while a tourist route planner might emphasize scenic detours. Below, the technical mechanisms—including algorithmic application, API integration, and multi-factor balancing—are detailed to illustrate how these components coalesce into a cohesive optimization framework.
Application of Optimization Algorithms in Multi-Stop Routes
The Traveling Salesman Problem (TSP) and Vehicle Routing Problem (VRP) form the core of multi-stop route optimization, each addressing distinct yet overlapping challenges. TSP focuses on finding the shortest possible route that visits a set of locations exactly once and returns to the origin, assuming a single vehicle and no capacity constraints. VRP extends this by incorporating multiple vehicles, delivery windows, and resource limitations, making it more suitable for commercial or fleet-based applications.Key Algorithmic Approaches:
Example Use Case:For guided driving applications, the choice of algorithm depends on the scenario:
A guided driving system for a delivery fleet might use a hybrid VRP solver to cluster stops by geographical proximity (exact method) and then apply a genetic algorithm to optimize the sequence of clusters (heuristic), reducing total travel time by 15–25% compared to naive approaches.
API Integration for Real-Time Data Fetching
Real-time data from mapping and traffic APIs is critical for dynamic route adjustments, ensuring that pre-optimized paths remain viable despite unforeseen changes. APIs such as Google Maps Directions API, OpenStreetMap Nominatim, and HERE Maps provide geospatial data, traffic conditions, and alternative route suggestions. Integration involves parsing API responses, validating data integrity, and applying corrections to the optimized route.Core API Functions for Route Optimization:
Example API Integration Workflow (Google Maps Directions API):
1. Request Formatting: Construct a URL with origin, destination, waypoints, and optional parameters (e.g., `avoid=tolls`, `departure_time`).
2. Response Handling: Parse JSON to extract `routes`, `legs`, and `steps`, then validate fields like `distance.value` (meters) and `duration_in_traffic` (seconds).
3. Dynamic Adjustment: Compare API-provided durations with baseline estimates; trigger re-optimization if deviations exceed a threshold (e.g., 20% increase in travel time).
Code Snippet: Fetching Directions with Python (Requests Library)Data Validation Considerations:import requests
def fetch_route(origin, destination, waypoints=None, api_key="YOUR_API_KEY"):
base_url = "https://maps.googleapis.com/maps/api/directions/json"
params = {
"origin": origin,
"destination": destination,
"key": api_key,
"alternatives": "true" # Enable fallback routes
}
if waypoints:
params["waypoints"] = "|".join(waypoints)
response = requests.get(base_url, params=params).json()
return response.get("routes", [])
Balancing Optimization Factors via Weighted Scoring
Multi-stop route optimization requires trade-offs between competing objectives, such as distance, time, fuel efficiency, and user preferences. A weighted scoring system assigns priorities to these factors, allowing the algorithm to compute a composite "cost" for each candidate route. The weights are derived from user inputs (e.g., "prefer highways") or system defaults (e.g., "minimize fuel consumption").Key Factors and Weighting Logic:
Weighted Score Formula:
\[Example Weighting Scheme:
\text{Route Score} = (w_d \times \text{Distance}) + (w_t \times \text{Time}) + (w_f \times \text{Fuel Cost}) + (w_p \times \text{Preference Penalty})
\]
Where:
\(w_d, w_t, w_f, w_p\) = Normalized weights (sum to 1). Preference Penalty: Incremental cost for violating user constraints (e.g., +100 for using a toll road if prohibited).
| Factor | Default Weight | User-Adjustable Range |
|---|---|---|
| Distance | 0.3 | 0.1–0.5 |
| Time | 0.4 | 0.2–0.6 |
| Fuel Efficiency | 0.2 | 0.1–0.3 |
| Traffic Avoidance | 0.1 | 0.0–0.2 |
Structuring JSON Payloads for Route Planner Backends
The backend of a guided driving route planner processes user inputs as structured JSON payloads, which define the optimization parameters, constraints, and preferences. A well-designed payload ensures compatibility with both algorithmic solvers and API integrations. Below is a standardized schema for multi-stop route requests, including required fields and optional extensions.Core JSON Payload Structure:
{
"metadata": {
"request_id": "uuid-v4-string",
"timestamp": "ISO-8601-formatted-date",
"user_id": "optional-user-identifier"
},
"route_parameters": {
"origin": {
"location": {
"lat": 40.7128,
"lng": -74.0060
},
"address": "New York, NY"
},
"destination": {
"location": {
"lat": 34.0522,
"lng": -1
Accessibility and Inclusivity in Route Planning
Universal route planning must account for diverse user needs to ensure equitable access and usability. While traditional navigation systems prioritize speed and efficiency, underrepresented groups—such as individuals with sensory, cognitive, or mobility impairments—often face barriers that limit their ability to use these tools effectively. Customizable features, adherence to accessibility standards, and integration with assistive technologies are critical to bridging these gaps. This section examines specific user groups, compliance requirements, technological compatibility, and real-world implementations that demonstrate measurable improvements in inclusivity.
Underrepresented User Groups and Customizable Route Planner Features
Route planners must adapt to the unique challenges faced by three key underrepresented groups: visually impaired users, non-native speakers, and drivers with mobility disabilities. Each group requires tailored features to ensure safe and intuitive navigation.
Visually Impaired Users
Visually impaired individuals rely on auditory and tactile feedback to navigate. Route planners should incorporate:
Non-Native Speakers
Language barriers can lead to misinterpretation of instructions, increasing navigation risks. Solutions include:
Drivers with Mobility Disabilities
Physical limitations (e.g., limited reach, dexterity, or strength) require adaptive interfaces and route optimizations:
Accessibility Standards Checklist for Route Planners
Compliance with Web Content Accessibility Guidelines (WCAG) 2.2 and Americans with Disabilities Act (ADA) Title III ensures route planners are usable by people with disabilities. Below is a structured checklist with examples of compliant design choices:Perceivable Information
Operable User Interface
Understandable and Robust
ADA Title III Compliance
Assistive Technologies and Implementation Challenges
The following table outlines assistive technologies compatible with route planners, their benefits, and key implementation challenges. Integration requires collaboration between developers, accessibility experts, and end-users to address technical and usability barriers.| Assistive Technology | Primary Use Case | Implementation Benefits | Challenges |
|---|---|---|---|
| Screen Readers (e.g., JAWS, NVDA, VoiceOver) | Auditory navigation for visually impaired users | Enables real-time route instructions, landmark descriptions, and error notifications. | Dynamic content handling: Screen readers struggle with live map updates (e.g., traffic reroutes). Solution: Use ARIA live regions to announce changes. |
| Haptic Feedback Gloves (e.g., Teslasuit, bHaptics) | Tactile direction cues for visually impaired or deaf-blind users | Provides directional vibrations for turns, stops, or hazards without visual reliance. | Standardization: No universal haptic language for navigation. Solution: Customizable vibration profiles with user testing. |
| Speech Recognition (e.g., Dragon NaturallySpeaking, Siri) | Hands-free control for users with mobility disabilities | Allows voice commands for route changes, destination entry, and accessibility filters. | Background noise interference: Outdoor use may degrade accuracy. Solution: Adaptive noise cancellation and confirmation prompts. |
| Augmentative Communication Devices (e.g., Tobii Eye Tracker) | Navigation for users with speech/motor impairments | Enables eye-tracking or switch-based input for route adjustments. | Latency: Delay in processing gaze inputs can disrupt real-time navigation. Solution: Prioritize critical commands (e.g., "Cancel Route") over non-urgent actions. |
| Braille Displays (e.g., Alva, Focus Blue) | Tactile route confirmation for visually impaired users | Provides braille output for waypoints, distances, and alerts. | Data volume limitations: Braille displays have limited character buffers. Solution: Prioritize essential information (e.g., "Turn left in 100m") and truncate secondary details. |
| Real-Time Captioning (e.g., Otter.ai, Live Transcribe) | Lip-reading support for deaf or hard-of-hearing users | Transcribes audio instructions (e.g., "Next turn in 500 meters") in real time. | Accuracy in noisy environments: Outdoor settings may reduce speech recognition reliability. Solution: Combine with visual alerts (e.g., flashing icons) for critical instructions. |
Case Studies of Inclusive Route Planner Implementations
Successful integration of accessibility features often results in measurable improvements in usability, adoption, and user satisfaction. Below are three case studies highlighting real-world applications, user feedback, and quantitative outcomes.Case Study 1: Google Maps’ Accessibility Mode (2020)
Advanced Visualization Techniques for Route Guidance
Route guidance systems leverage cutting-edge visualization techniques to enhance driver comprehension, reduce cognitive load, and improve navigation accuracy. Advanced methods such as augmented reality (AR) overlays, 3D terrain modeling, and dynamic progress maps transform static routes into interactive, context-aware experiences. These techniques integrate real-time data, spatial analytics, and adaptive rendering to ensure seamless navigation across urban, off-road, and rural environments. Below are structured approaches to implementing these visualizations, supported by technical tools and data sources.Augmented Reality Overlays for In-Car Navigation
AR overlays project navigation cues directly onto the driver’s field of view, minimizing distractions from traditional screen-based interfaces. Turn-by-turn arrows rendered on windshields or dashboards use transparent, semi-opaque layers to maintain visibility without obstructing external visibility. The rendering process involves:Implementation Steps:
- Hardware Integration: Deploy AR head-up displays (HUDs) or smartphone-based AR glasses (e.g., Google Glass Enterprise) with high-resolution cameras and depth sensors. For dashboard projections, use laser-based or microLED HUDs with 20–30° field of view.
-
Software Pipeline:
- Spatial Anchoring: Use ARKit (iOS) or ARCore (Android) to anchor virtual objects to real-world coordinates via SLAM (Simultaneous Localization and Mapping). For vehicles, integrate with CAN bus data for precise vehicle positioning.
- Rendering Engine: Employ Unity or Unreal Engine to generate real-time 3D overlays, with shaders optimized for transparency and anti-aliasing.
- Data Fusion: Combine GPS/IMU data with high-definition (HD) maps (e.g., HERE, TomTom) to align AR cues with road geometry.
- User Customization: Allow drivers to adjust overlay brightness, font size, or arrow style (e.g., solid vs. dashed lines) via in-car touchscreens or voice commands.
A delivery driver navigating a congested city uses a windshield HUD to see AR arrows pointing to the next left turn, while a secondary dashboard display shows a 3D bird’s-eye view of traffic conditions. The system dynamically prioritizes overlays based on proximity to the next maneuver.
Generating 3D Terrain Models for Off-Road and Rural Routes
Off-road and rural navigation requires terrain-aware routing, where elevation changes, obstacles, or unpaved surfaces influence path selection. 3D terrain models provide drivers with contextual awareness, reducing the risk of vehicle damage or getting stranded. The generation process involves:Tools and Workflow:
-
Data Processing:
- LiDAR Point Clouds: Convert to mesh using CloudCompare or PDAL, then refine with Blender’s sculpting tools for smooth terrain transitions.
- Satellite Imagery: Apply photogrammetry (e.g., Pix4D, Agisoft Metashape) to generate orthomosaics and digital surface models (DSMs).
- Hybrid Models: Merge LiDAR-derived elevation with satellite-derived land cover (e.g., NDVI for vegetation density) for accurate obstacle detection.
-
3D Engine Integration:
- Cesium: Load terrain data via Cesium Terrain Provider, with dynamic LOD (Level of Detail) adjustments for performance. Example:
                const terrain = viewer.terrainProvider = new Cesium.CesiumTerrainProvider({

                    url: 'https://assets.agi.com/stk-terrain/world',

                    requestVertexNormals: true

                });
- Blender for Pre-Processing: Export terrain as glTF/glb for lightweight runtime loading, with baked shadows and water simulations.
- Cesium: Load terrain data via Cesium Terrain Provider, with dynamic LOD (Level of Detail) adjustments for performance. Example:
-
Runtime Adaptations:
- Obstacle Avoidance: Overlay real-time LiDAR scans (e.g., Velodyne sensors) to highlight rocks or ditches in AR mode.
- Accessibility: Provide tactile feedback (e.g., vibration) for steep inclines or low bridges.
A farmer using a guided driving system in a vineyard receives a 3D terrain model showing upcoming rows of grapevines, with AR overlays indicating optimal steering angles to avoid crushing plants. The system cross-references satellite-based vineyard maps with real-time GPS to adjust routes dynamically.
Designing Animated Progress Maps for Real-Time Vehicle Movement
Animated progress maps visualize the vehicle’s trajectory against the planned route, reinforcing spatial awareness and reducing navigation errors. Effective designs incorporate timing, color gradients, and responsive scaling to accommodate different screen sizes and user preferences. Key components include:Implementation Guidelines:
-
Animation Framework:
- SVG Path Morphing: Use D3.js or Snap.svg to animate a polyline representing the route, with interpolation between waypoints. Example:
                d3.select("path.route").attr("d", d3.line()

                    .x(d => projection([d.lon, d.lat])[0])

                    .y(d => projection([d.lon, d.lat])[1])

                );
- Canvas-Based Rendering: For high-performance needs, use WebGL (e.g., Three.js) to render smooth transitions with GPU acceleration.
- SVG Path Morphing: Use D3.js or Snap.svg to animate a polyline representing the route, with interpolation between waypoints. Example:
-
Dynamic Styling:
- Gradient Transitions: Apply CSS `linear-gradient` to the route path, with opacity fading from 100% (current position) to 0% (destination).
- Event Highlights: Pulse or glow the vehicle icon when approaching turns or speed bumps.
-
Responsive Design:
- Media Queries: Adjust map scale and label font sizes using `@media (max-width: 600px)` to ensure legibility on mobile devices.
- Touch Targets: Increase the size of interactive elements (e.g., route recalculations) to 48x48px for accessibility.
A rideshare driver’s progress map shows a smooth animation of their vehicle moving along the route, with a 5-second delay between real-time position and animated position to reduce visual clutter. The system highlights nearby traffic incidents in red, while the driver’s predicted arrival time updates dynamically based on speed.
Heatmaps for Traffic Congestion and Route Popularity Visualization
Heatmaps overlay aggregated data (e.g., GPS traces, traffic cameras) onto base maps to reveal patterns in congestion, accident hotspots, or popular routes. These visualizations help drivers anticipate delays, optimize fuel efficiency, or discover alternative paths. Generation involves:Effective route planning in guided driving demands a balance between technical sophistication and user accessibility, ensuring solutions meet the demands of diverse populations and dynamic conditions. From leveraging algorithms like the Traveling Salesman Problem to integrating augmented reality overlays, the future of navigation lies in adaptive, data-driven systems that prioritize safety, efficiency, and inclusivity. By adopting these strategies, developers can create route planners that not only optimize paths but also enhance trust and confidence among drivers of all backgrounds and abilities.
The journey toward smarter navigation is ongoing, with continuous advancements in AI, real-time data processing, and assistive technologies paving the way for more intuitive and reliable guided driving experiences. As industries and users increasingly rely on multi-stop route optimization, the principles outlined here serve as a foundation for building systems that are both innovative and universally accessible.
Leave a Comment
Comments are moderated before appearing. The data you submit is processed according to the Privacy Policy of ir.msu.ac.zw.